Roof measurements, outlines and a 3D model from drone photos. Fully offline, perpetual license.
You don't need an expensive survey drone
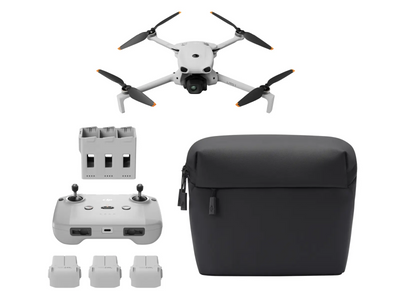
FlightLab Roof works with ordinary camera drones — including the light models under 250 grams. No RTK, no extra hardware, no ground control points. What the camera writes into the image file about position and orientation is all the software needs.
DJI Mini · Potensic Atom · and comparable camera drones with GPS
Download the free trial
14 days, full functionality. Compute, measure, export — nothing is locked. No sign-up, no email address, no payment details.
260 MB · Windows 10 or 11 (64-bit) · NVIDIA graphics card required
Signed by Drone Life Systems FlexCo · License terms (Terms of Service, Part F, in German) · Uninstall any time via Windows Settings → Apps.
Tip for buying later: the device ID is shown in the program. Have it ready when you order and enter it in the field next to the product — the key then arrives by email automatically right after payment.
What you measure with it
- Roof area on the slope — not the footprint. A roof at 30 degrees has about 15 % more area: on a 2,150 sq ft footprint that is a good 320 sq ft of extra covering.
- Net area with cut-outs — trace skylights, chimneys and existing PV, and the software subtracts them. When you save, each cut-out counts toward the roof area whose outline it lies in — even if it was drawn on a different area. What you see is the figure you order.
- Pitch in degrees and percent, plus the aspect — for laying out the PV system.
- Edge lengths for ridge, eaves, hips, valleys and verges, measured on the slope, not in plan. The CSV adds up distances with the same name.
- Check your figures — re-measure an edge whose length you know. If it's off, you can calibrate the model with one click.
- Meters or feet — the display and the exports switch between meters, international feet and US survey feet; the model itself is always computed in meters.
- Pass the model on to PV planning, the sheet-metal shop or the structural engineer — OBJ with texture, PLY, LAS, LAZ or E57.
- Fully offline — no cloud account, no telemetry, nothing about you or your projects leaves your PC. Activation works offline too. The program asks the outside world one thing only: whether a newer version exists — once at startup in the background, and when you click Check for updates in the “About FlightLab” window. Without internet it stays silent.
- English and German — the interface and every export.
Taking the photos: the quick guide from the program
Ideally one circle around the house, as far as possible, and one pass straight down from above: 40 to 60 photos in total for a detached house, with a short stop for every photo — the animation shows how. The program shows the same quick guide at startup and any time under ⓘ at the top right.
How it works
- Load the photos
- Clean up the point cloud if needed
- Measure
- Export dimensions, outlines and 3D models
After loading, you outline the roof on the overview image and confirm the selection. The program then computes point cloud, mesh and texture in one run.
Before starting, the program works out whether the graphics memory is enough. If the card is too small for the usual computation, it says so first and, where possible, offers a smaller image size.
The four measuring tools
| Check/Calibrate | Re-measure an edge of known length: deviation in the chosen unit and in percent — and, if you want, calibrate the model with one click |
| Distance | Length from point to point, kinks included, with the total length; with two points also slope distance, horizontal distance, height difference and pitch in degrees and percent — for ridge, valley, hip, verge and eaves. The CSV adds up distances with the same name. |
| Roof area | Area on the slope and in plan, pitch, aspect, perimeter — with cut-outs for skylights, chimneys and existing PV |
| Polyline | A line that lays itself onto the roof surface — shows kinks and angles, for planning flashings in CAD (DXF); it follows the computed 3D model (the mesh) with a point every 5 cm (2 inches), so narrow features like a firewall or a chimney come out as wide as they are |
Above the tools you choose what a click snaps to: Mesh, Points, Corner, Edge or Free. Mesh hits the computed surface between the measured points — the default as soon as a mesh exists, because on a flat roof plane it averages out the noise of individual points. Points snaps to the nearest measured point — better than the mesh at edges, because the mesh rounds them. With Corner, a click near a roof corner lands on the intersection of the roof edges; with Edge, it lands on the nearest roof edge — for points along the ridge, hips, verges and eaves. The program finds the edges in the point cloud by itself; if it finds no suitable edge (for Corner: not two), it places the point as with “Points” and says why. Free places the point where you click, even where nothing was measured. Next to every saved measurement there is a checkbox: checked, it stays in the view — areas hatched, distances and polylines as lines — with its name and main figure, for areas also the pitch, polylines with the name only. The label stays the same size at every zoom and moves out of the way when you place a cut-out under it; the checkbox is saved with the project. The figures are the same as in CSV and DXF.
Cleaning up the point cloud
Not every measured point belongs to the roof: branches reaching over the eaves, a car in the driveway, isolated stray points in mid-air. You remove such clutter before measuring.
| Lasso | Draw an outline around the clutter and delete the selection — or the other way round, keep only the selection and discard everything else. The selection remembers the view you drew it in. |
| Remove outliers | Runs the filter for isolated stray points over the point cloud once more. |
| Undo | Every step can be undone, up to twenty steps — even after closing the program. |
As soon as you remove something, the Mesh layer shows “outdated” and, next to it, the Compute button. Remove as much as you like, then click it once: mesh and texture are recomputed from the cleaned point cloud, so you measure on the cleaned data.
What comes out
| Point cloud | PLY, LAS, LAZ, E57 |
| 3D model | OBJ, mesh PLY, textured OBJ with location file |
| Dimensions and outlines | CSV, DXF |
The CSV contains areas, distances and polylines, plus totals for distances with the same name; check lengths are not included. The CSV follows the selected language: separator, decimal mark and column headers suit English Excel as well as German. The textured OBJ is the format for PV planning. Alongside the model file, a location file is written so that the building sits in the right place in PV*SOL and the solar irradiation is computed for your site.
Roof or Reality?
If you need terrain models, classification into ground, vegetation and buildings, a comparison of two flights, volume calculation, orthophotos, or more than 500 photos in one 3D model, you need FlightLab Reality.
System requirements
| Operating system | Windows 10 or 11, 64-bit |
| Memory | 16 GB, more doesn't hurt |
| Graphics card | NVIDIA with CUDA, 8 GB of graphics memory recommended, GeForce GTX 10xx or newer. If the usual computation does not fit on the card, the program offers a smaller image size; below 2 GB it does not compute. Without an NVIDIA card the program does not compute — AMD and Intel graphics are not supported. |
| Storage | SSD; about 225 MB per photo while computing, so about 7 GB for 30 photos and about 18 GB for 80. |
| Internet | not required — not even for activation |
The program checks the graphics card and the compute core at startup and tells you whether they are sufficient.
License and activation
| License type | Purchase license, perpetual, one workstation |
| Subscription | none |
| Trial | 14 days, full functionality |
| Activation | Enter the device ID in the field next to the product when you buy — the key arrives by email automatically right after payment. The ID is shown in the program. If you don't have it at hand when ordering, leave the field empty and send it to roof@flightlab.at afterwards; the key arrives the same way. It is applied offline, without internet. |
| Change of computer | free once per year — for a defect, a new machine or any other reason. A short message with the new device ID to roof@flightlab.at, and the new key comes back. |
| Language | English and German — inquiries in English are answered in English |
The license covers one workstation and is tied to the device. If the computer breaks or is replaced, you get a new key free once per year — so the license stays bound to one workstation and does not keep wandering between several machines. The program transmits nothing about you and nothing from your projects — activation works offline too. The only outbound request is the check for a newer version: once at startup in the background and when you click Check for updates in the “About FlightLab” window; what is transmitted is the software's version number and what every internet request carries anyway. If a newer version exists, Update available appears at the top; Download saves the setup to your “Downloads” folder, the program checks its size and the publisher's signature, and Install now starts the setup, which installs over the existing version — projects, activation and settings are kept.
Drone Life Systems FlexCo · Unterfreundorf 17, A-4076 Unterfreundorf, Austria · Company register FN 624110i · VAT ID ATU80636956 · GISA 37719746
Security reports: security@flightlab.at